
The Breakdown
- CMU researchers created a robotic fingertip to help robots handle delicate tasks without breaking fragile or tiny objects, such as pills and potato chips.
- The new fingertips attach directly to researchers’ DeltaHands device, adding multisensory versatility to a flexible, low-cost robotic hand.
- Each fingertip measures squeezing pressure and uses a plastic fingernail to capture microvibrations.
* * *
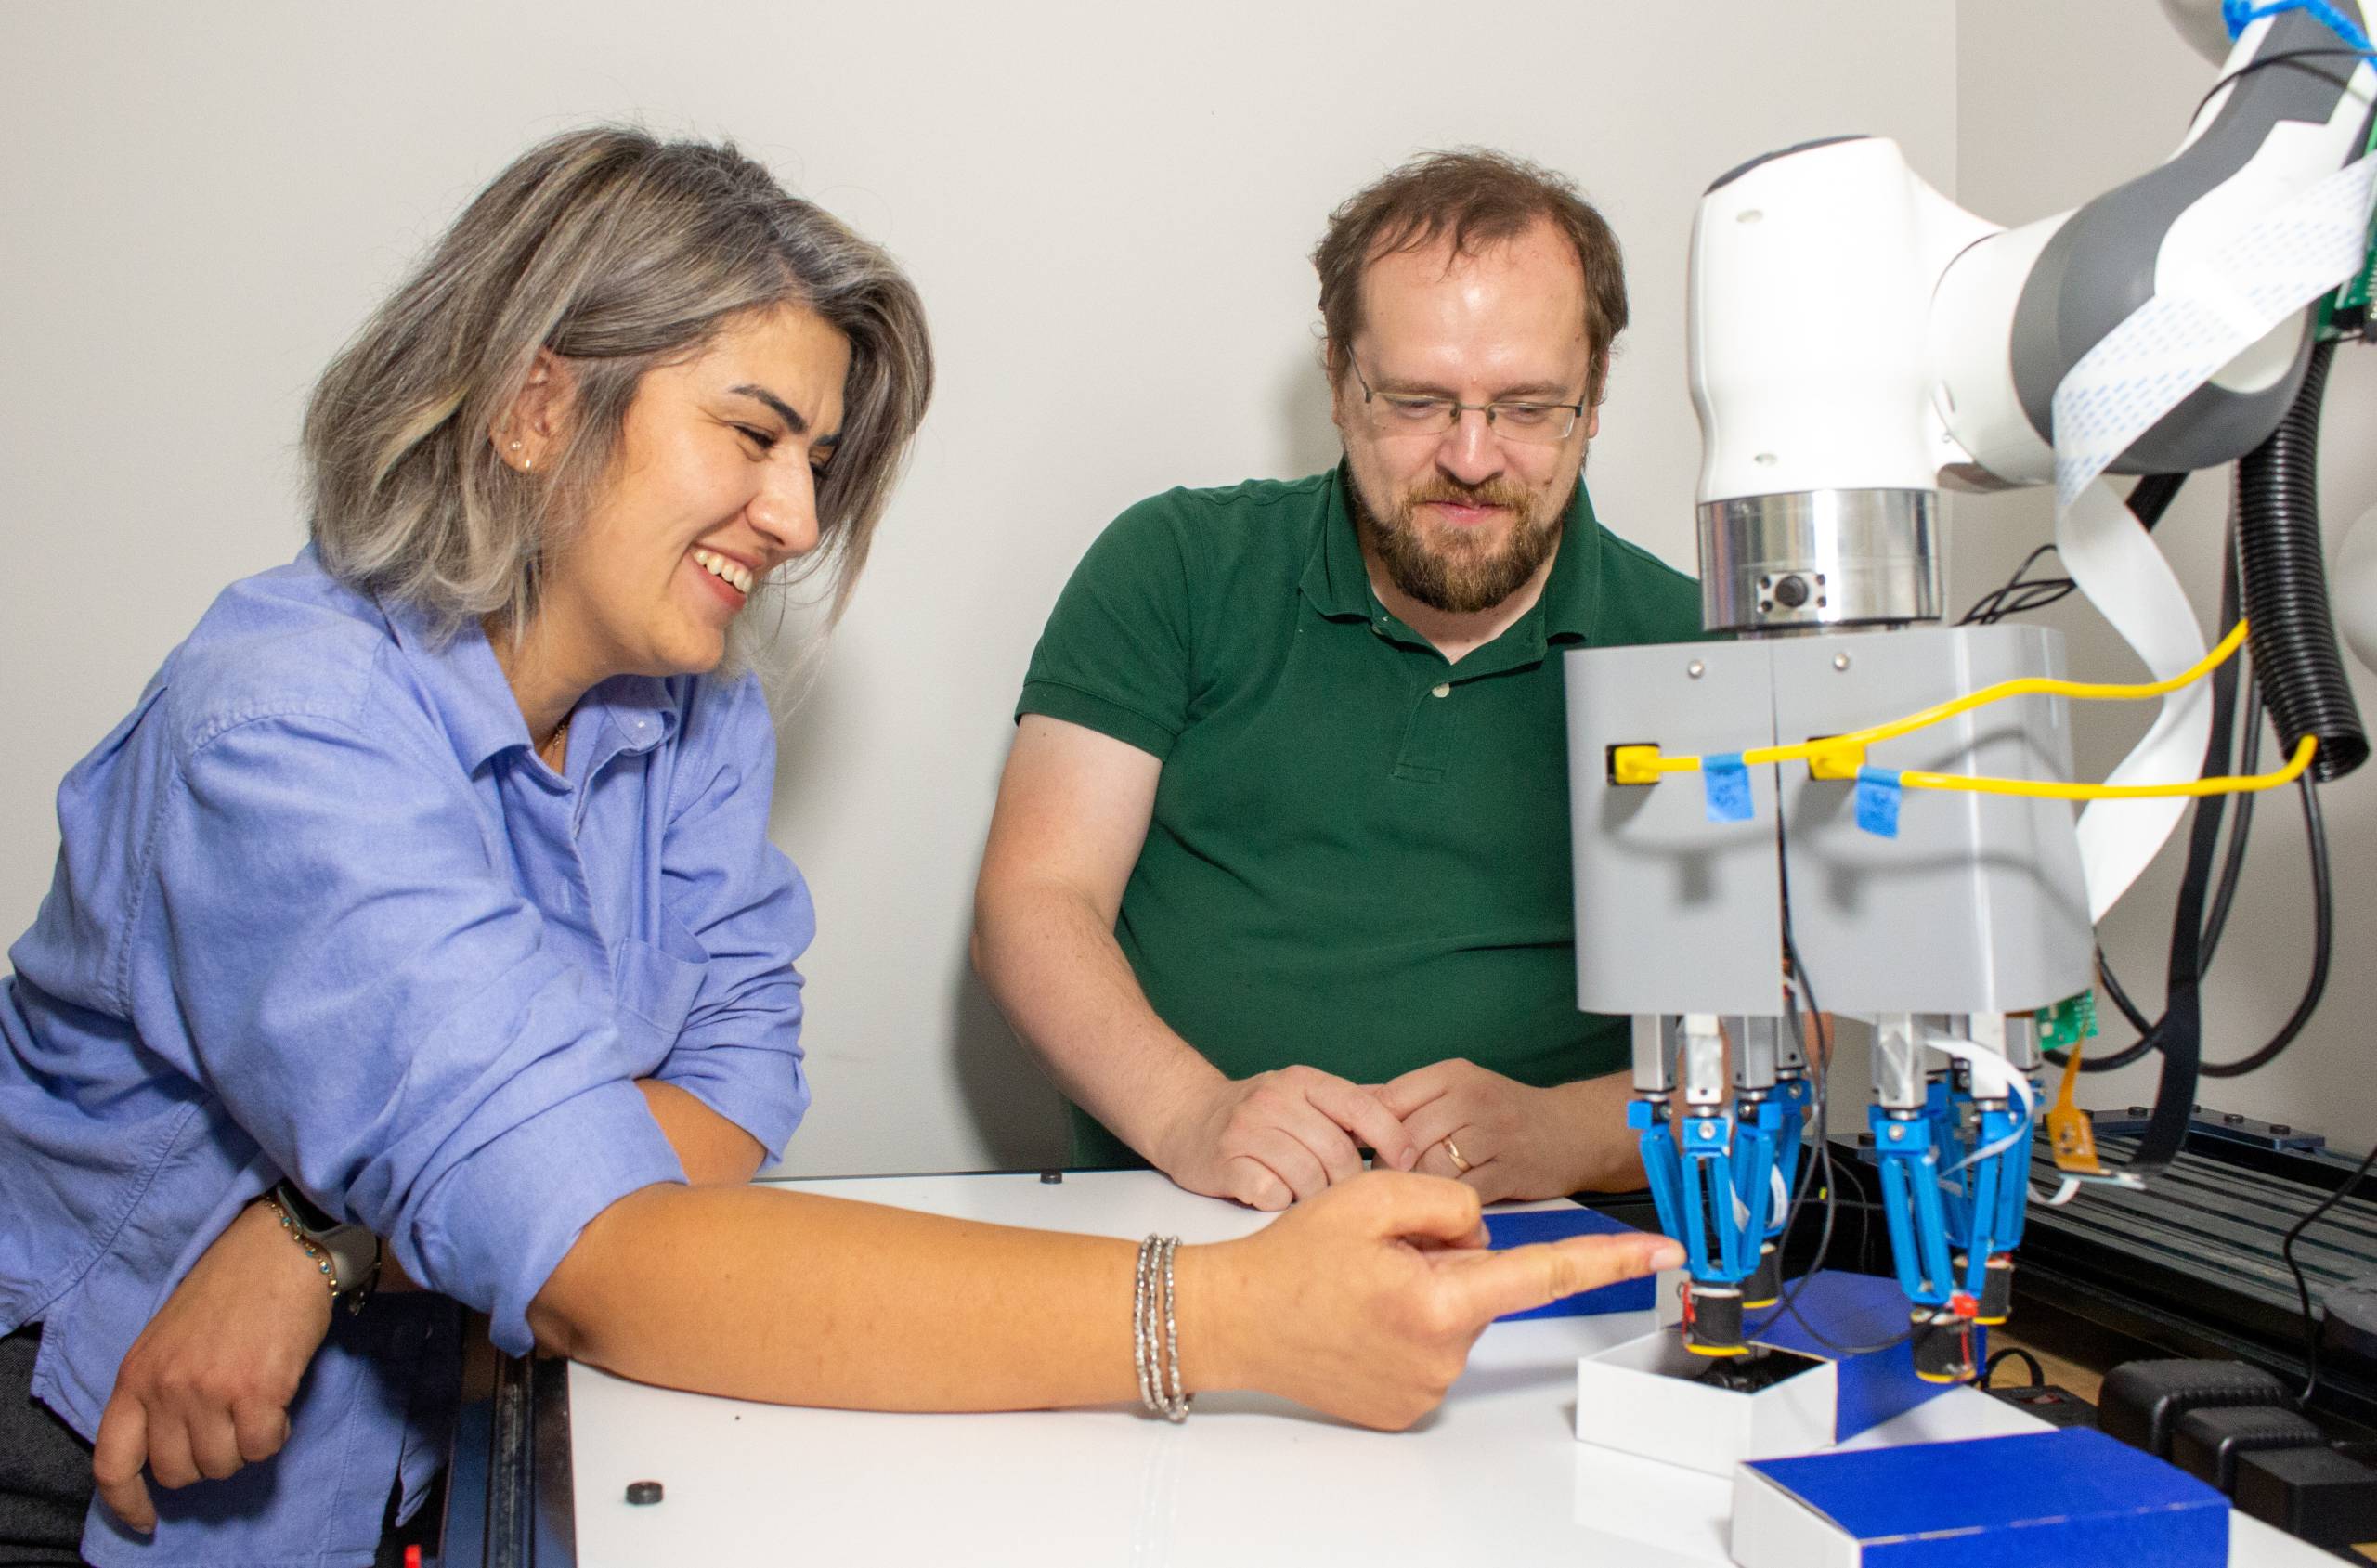
Carnegie Mellon Robotics Institute faculty Zeynep Temel (left) and Oliver Kroemer (right) observe a robotic hand equipped with new human-inspired sensing fingertips.
Researchers in the Carnegie Mellon University Kenneth C. Griffin School of Computer Science designed a new type of robotic fingertip that combines multiple senses to handle small, delicate objects. The technology could help a robotic home assistant pick up a specific number of pills — a challenging task because the tiny objects are difficult to grasp and easy to break.
The low-cost, versatile fingertips are inspired by their human counterparts and include familiar elements like a fingernail.
“Dexterity is a frontier area of robotics, and we’re making rapid progress,” said Oliver Kroemer, an associate professor in the Robotics Institute (RI). “However, fine manipulation is still very much an open challenge, and that’s why we wanted to focus on it.”
The work builds on the team’s DeltaHands project, which received funding from the National Science Foundation to create a low-cost, highly customizable flexible robotic hand that could turn the pages of a book, grab an oddly shaped item or complete other tasks typically difficult for a robot. The robot can have anywhere from one to six finger-like devices and, because many components are 3D printed, can be easily modified for specific tasks.
This research builds on the DeltaHands device, creating human-inspired fingertips that attach to it and add more versatility for manipulating objects.
Researchers used a strain gauge and microphone to enable the robot to sense what it was grasping and make decisions about how to handle it. The strain gauge measures the squeezing pressure the finger applies so the hand knows exactly how hard it’s pinching. The contact microphone sits behind a tiny plastic fingernail, capturing high-frequency vibrations as the finger slides over an object or bumps into a surface. Wrapped in a soft silicone skin for grip, the setup lets the robot hear subtle textures, detect slipping and note hidden edges it may catch on. All told, it cost less than $100 per fingertip, compared to $800 to create a similar device from off-the-shelf products.
“We show how multimodal touch can directly support both perception and control during manipulation,” said Zhuowei Xu, an alumnus from the College of Engineering who worked on the project while completing his master’s degree in mechanical engineering “By combining force and vibrotactile sensing, the robot can interact with objects in different ways depending on the task: from adjusting its grasp when an object starts to slip, to locating fine features that are difficult to see, to actively identifying properties of objects that are completely hidden from vision and using that information to guide the next action.”
To test manipulation, researchers experimented with counting and unstacking paper cups; detecting the material composition of various items, like coarse fabric or wax paper, through micro-vibrations; and grasping fragile items, such as tofu cubes and potato chips. Counting and unstacking cups allowed researchers to test how the fingertips improved manipulation with blocked visuals. The nail on the fingertip, which protects the microphone, was able to slide along the edge of the cups and count them. The microphone allowed researchers to detect differences in materials’ microvibrations, learn from those differences and detect what kind of material it was touching.
The fingertips enable a level of sensing and perception that opens the door for new ways a robotic assistant could help someone in their home.
“I don’t want a robot that does the fun things I enjoy doing around the house,” said Zeynep Temel, an associate professor in the Robotics Institute. “What I want is to be in my machine shop working on my own projects or in my kitchen working on a new recipe. And while I don’t want a robot doing that work for me, I’d love a helper robot that can hand me the right materials, one that knows the difference between a box of nails and a box of rubber bands or if the rice jar is empty or not.”
The researchers presented their work at the 2026 Intelligent Robots and Systems Conference last week in Pittsburgh. The team plans to continue developing this robotic hand, exploring how to expand sensing from the fingertips to the whole device. In addition to the members mentioned, the team included RI Ph.D. alumni Zilin Si and Kevin Zhang.
For More Information: Aaron Aupperlee | 412-268-9068 | aaupperlee@cmu.edu